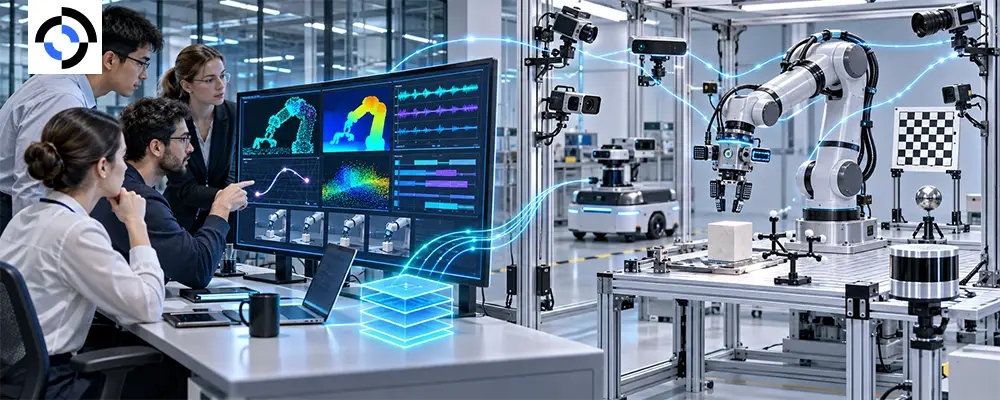
Research teams rarely lack ideas. They lack hours. Every month spent building rigs, calibrating cameras and recruiting operators is a month not spent on the model, which is why more labs now choose to outsource robot data collection.
But robotics sensor data collection is not generic data labeling. Cameras, depth sensors, force-torque cells and joint encoders must be synchronized, calibrated and logged in a way your training pipeline can trust. This guide explains when outsourcing makes sense, how to specify a multimodal dataset, and how to evaluate robotics dataset collection services without surprises.
When outsourcing makes sense
Outsourcing tends to pay off in four situations: you need volume faster than your lab can staff, your team’s strength is modelling rather than hardware operations, you need diversity across scenes and sites, or you need collection to stay repeatable across quarters. In-house collection still wins for early prototyping on a single rig. Our build vs buy cost analysis works through the break-even, and our post on off-the-shelf vs bespoke manipulation datasets explains when custom collection is worth it.
Specify the sensor stack before you ask for a quote
Vague specifications produce vague data. For sensor data collection for embodied AI, define each modality and the parameters that matter.
| Modality | What it captures | What to specify |
| RGB and RGB-D cameras | Scene and object appearance, depth | Resolution, frame rate, mount positions, calibration method |
| LiDAR and point clouds | 3D geometry for mobile robots | Sensor model, scan rate, point cloud format |
| Force-torque and tactile | Contact and grasp state | Sampling rate, axes, logging approach |
| Proprioception | Joint states, end-effector pose | Frequency, units, joint state logs |
| Audio and language | Instructions, ambient sound | Microphone placement, transcript format |
Multimodal robot sensor data is only as useful as its alignment, which brings us to the part most teams underestimate.
Synchronization and calibration decide usability
The Data-Centric AI movement defines its core idea simply: “Data-centric AI is the discipline of systematically engineering the data used to build an AI system.” Synchronization is exactly that kind of engineering. If a wrist camera and a force sensor disagree about timing by even a few frames, the policy learns a world that never existed.
Ask every provider about hardware triggers, clock synchronization, drift reporting and recalibration cadence. Our guide to multi-camera synchronization explains what a defensible answer looks like, and our RGB-D collection post covers depth-specific pitfalls.
Reproducibility and data lineage for research
Research data has a higher bar than production data because someone, eventually, will try to reproduce your results. Require versioned task scripts, sensor and firmware records, per-session calibration files, episode manifests and documented train and test splits. Clarify consent and licensing early if you plan to publish or release the dataset.
Formats matter too. Confirm that delivery arrives in a structure your tooling reads natively, whether HDF5, ROS bag exports or a LeRobot-style layout. Our posts on trajectory data formats and imitation learning dataset structure help you decide before collection starts.
Evaluating robotics dataset collection services
- Review sample data first. Ask for a real sample with logs, calibration files and metadata, not a brochure.
- Inspect the QA process. Look for automated checks plus human review and per-batch reject reporting, as described in our robotics data QA pipeline.
- Test specification flexibility. Research evolves. Can the provider change sensors, tasks or scenes mid-program without a restart?
- Understand the staffing model. Dedicated teams suit sustained programs; crowdsourced capacity suits breadth. A hybrid model often fits best.
- Check security and residency. Review access controls and data residency options before any footage is captured.
How Roborax supports embodied AI research teams
Roborax runs multimodal sensor capture programs with synchronized streams, calibration reports and per-episode metadata, delivered in the formats your pipeline expects. Because we also provide annotation and labeling and evaluation benchmarks, research teams can keep collection, labeling and testing under one accountable partner rather than three.
“Research moves faster when the sensor data arrives already trustworthy.” — Roborax data operations team
Frequently asked questions
Q: Which sensors can an outsourced program capture?
A: Typical programs combine RGB and RGB-D cameras, joint-state logs, force-torque and tactile sensors, LiDAR and audio. The right mix depends on your robot and task, so specify modalities, rates and mounting positions up front.
Q: How do we protect our research IP?
A: Use clear data-ownership terms, restricted access controls and defined deletion policies, and confirm where data is stored and processed. Raise these before collection begins.
Q: Can we start with a small pilot?
A: Yes, and you should. A pilot reveals calibration quality, synchronization accuracy and QA rigor at low cost before you scale.
If you are planning a dataset for your next paper or model, tell us what you are training and we will propose a sensor stack, volume and QA plan to match.