Depth Camera Calibration Best Practices for Data Teams
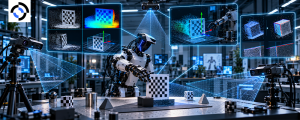
For robots operating in the physical world, seeing an object is only the beginning. A robot must also understand how far away it is, where
Humanoid data collection covers whole-body trajectories, dexterous hand manipulation, bipedal locomotion, and loco-manipulation — the full stack of behaviors a humanoid policy needs to learn. We collect across 24 platforms so your model transfers across embodiments.
Humanoid data is hard
High DoF, full-body coordination, and platform-specific kinematics make humanoid collection the most complex data work in robotics. We’ve built the operator bench and rig fleet to handle it.
8 active humanoid programs.
24 platforms supported.
50K+ trajectories delivered.
Where we collect
41+ delivery centers across 12 countries. Every program runs from a Roborax hub near your target time zone.
Asia Pacific
India · Philippines
Americas
USA · Canada · Colombia · Jamaica · El Salvador · Belize
EMEA
UK · Albania · Kosovo · Morocco
Four data classes that bipedal foundation models need but generic data pipelines rarely produce.
Coordinated upper + lower body kinematics, 30Hz, in your robot frame.
Same task captured across multiple humanoid morphologies for transfer learning.
Per-finger joint logs and grasp state for complex object handling.
Walking while carrying, reaching while balancing — the chains that break generic policies.
Four stages that produce humanoid-ready data, not adapted-from-arm data.
Bring up your humanoid or use ours. Joint calibration captured. URDF locked.
Whole-body teleoperators trained on your kinematic envelope and balance constraints.
Trajectories captured against your acceptance bar. Stability and contact monitored.
Same trajectory rendered in multiple morphologies where the platform supports retargeting.
Production humanoids, research bipeds, and the rigs that retarget between them.
Production
Production
Production
Production
Research
Production
Four verticals. One data partner.
Long-horizon tasks in real environments.
Pick-pack-place across real SKU diversity.
Procedure-grade demos on surgical platforms.
Remote operator-driven data collection.
In-person task demos for imitation learning.
RGB-D, LiDAR, force, and tactile streams.
FAQ
Across the spectrum — from pre-alpha hardware needing initial motion primitive data to commercial-stage teams scaling up training data for a specific deployment environment. There is no minimum stage.
The gap between “our policy works in the lab” and “our policy works reliably in varied real-world conditions”. We close that gap by adding diverse, high-quality real-world demonstration data.
Yes. We provide training data for teams building general-purpose robot foundation models that need broad task coverage across multiple platforms and environments.
From the blog
Lessons from 50,000 Humanoid TrajectoriesWhat 50,000 trajectories taught us about humanoid data collection.
From the blog
Humanoid Robot Training Data: How Much Do You Need?Volume requirements for humanoid foundation model training.
Tell us the platform, the tasks, and the morphology mix. Six weeks to first cross-embodiment batch.
FROM THE FIELD

For robots operating in the physical world, seeing an object is only the beginning. A robot must also understand how far away it is, where

What a wearable capture rig must carry, why field logistics stall programmes more than engineering does, consent in shared spaces, and quality controls that work.
A robot may have excellent sensors, sophisticated actuators, and a powerful learning model—but if the data used to train that robot is poorly synchronized, the
A robot can see an object without understanding how it feels. A camera can identify a cup, estimate its position, and guide a robotic hand
A mobile robot cannot navigate a warehouse, factory, hospital, or outdoor environment from camera images alone. It needs to understand distance, geometry, obstacles, surfaces, and
Human demonstration and teleoperation produce different action labels with different traps. Plus the third category, intervention data, that most teams never budget for.