Depth Camera Calibration Best Practices for Data Teams
For robots operating in the physical world, seeing an object is only the beginning. A robot must also understand how far away it is, where
Mobile manipulation data covers long-horizon tasks where a robot must navigate, reach, grasp, and interact across real environments — kitchens, offices, retail floors, and homes. Each episode chains 5–15 primitive actions into sequences your policy learns end-to-end.
Long-horizon is hard
Mobile manipulation episodes are 10–60x longer than tabletop pick-and-place. Our operators are trained for sustained, multi-step demos without quality drift.
5 mobile platforms.
12 task domains.
30+ specialized operators.
Where we collect
41+ delivery centers across 12 countries. Every program runs from a Roborax hub near your target time zone.
Asia Pacific
India · Philippines
Americas
USA · Canada · Colombia · Jamaica · El Salvador · Belize
EMEA
UK · Albania · Kosovo · Morocco
Four streams that capture what happens between picking the object and finishing the task.
Multi-step task captures, 5–30 minutes per episode, with goal annotations.
Combined movement and contact logs in a single timeline. Your fusion stack ready.
Per-episode occupancy and semantic maps for retraining or replay.
Operator recovery from mid-task failure, labeled for imitation or RL.
A four-stage pipeline designed for real homes, kitchens, and offices — not lab benchtops.
Real homes, kitchens, offices, or studios. Lighting and clutter matched to deployment.
Bring up your mobile manipulator. Calibration and SLAM verified.
Multi-step task captures with operator decision points logged.
Targeted re-capture of failure modes from your production model logs.
Research workhorses and production deployments.
Research
Research
Legacy
Quadruped
Bimanual
Research
Four verticals. One data partner.
Whole-body trajectories across 24 platforms.
Pick-pack-place across real SKU diversity.
Procedure-grade demos on surgical platforms.
ALOHA, Stretch, TIAGo, Spot+Arm, and custom.
RGB-D, LiDAR, force, and tactile streams.
Remote operator-driven data collection.
FAQ
Healthcare (medication delivery, patient assist), hospitality (room service, cleaning), retail (restocking, customer assist), and logistics (last-mile fulfillment in mixed human-robot environments).
We capture across multiple site configurations — different room layouts, shelf heights, door widths — so your policy is not overtrained on a single floorplan. Multi-site capture is standard for mobile manipulation programs.
From simple point-to-point navigation to complex multi-step loco-manipulation tasks involving navigation, object retrieval, and handover — all in environments with dynamic human presence.
From the blog
Warehouse Picking Robots: What Your Training Data Strategy Is MissingData requirements for grasping, picking, and placing.
From the blog
The Embodied AI Data FlywheelWhy mobile manipulation programs need continuous data investment.
Tell us the platform, the environment, and the task length. Four weeks to first long-horizon batch.
FROM THE FIELD

For robots operating in the physical world, seeing an object is only the beginning. A robot must also understand how far away it is, where

What a wearable capture rig must carry, why field logistics stall programmes more than engineering does, consent in shared spaces, and quality controls that work.
A robot may have excellent sensors, sophisticated actuators, and a powerful learning model—but if the data used to train that robot is poorly synchronized, the
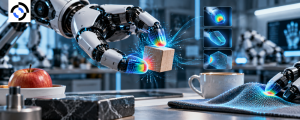
A robot can see an object without understanding how it feels. A camera can identify a cup, estimate its position, and guide a robotic hand
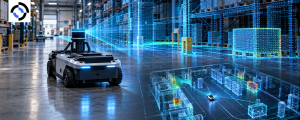
A mobile robot cannot navigate a warehouse, factory, hospital, or outdoor environment from camera images alone. It needs to understand distance, geometry, obstacles, surfaces, and
Human demonstration and teleoperation produce different action labels with different traps. Plus the third category, intervention data, that most teams never budget for.