Depth Camera Calibration Best Practices for Data Teams
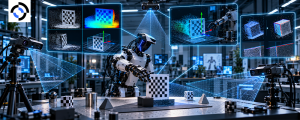
For robots operating in the physical world, seeing an object is only the beginning. A robot must also understand how far away it is, where
Simulation lets teams pre-train policies safely at scale before real-world deployment. But sim-to-real transfer fails when simulation runs are not paired with real-world validation — the gap between sim behavior and physical behavior kills policies that look good in training.
Use cases we support:
Why teams partner with us:
Sim alone isn’t enough — the gap kills policies.
We pair every sim dataset with real-world validation trajectories. Our 91% transfer rate comes from this pairing discipline, not from simulation quality alone.
10K+ sims per day
91% sim-to-real transfer rate
paired real + sim datasets
Where we collect
41+ delivery centers across 12 countries. Every program runs from a Roborax hub near your target time zone.
Asia Pacific
India · Philippines
Americas
USA · Canada · Colombia · Jamaica · El Salvador · Belize
EMEA
UK · Albania · Kosovo · Morocco
NVIDIA Isaac, DeepMind MuJoCo, Genesis, Habitat Lab, plus custom Blender pipelines.
NVIDIA
DeepMind
Custom physics
Meta
Asset creation
Your engine
Four output classes designed to close the sim-to-real gap, not just produce synthetic frames.
Domain randomization across textures, lighting, physics, and object placement.
Identical scenes captured in both sim and reality for direct gap measurement.
Controlled-variable runs for ablations and curriculum design.
Synthetic generated to match your real-world statistics.
A pipeline that ends with sim-to-real metrics, not just rendered images.
Build the parameterized scene with your team. Variables and ranges locked.
Sweeps across textures, lighting, physics, and asset variants.
Quality gates filter failed sims. Per-batch realism metrics computed.
Transfer rate measured against held-out real captures. Reported per batch.
Six hardware families. One data partner.
Whole-body trajectories for bipedal robots.
Long-horizon tasks on mobile platforms.
High-throughput arm data for factory settings.
Domain-randomized scenes and sim transfers.
Held-out test sets and success-rate scoring.
Rare scenarios your policy faces in production.
FAQ
Isaac Sim, Mujoco, PyBullet, Gazebo, and Genesis as standard. We can integrate with proprietary simulators given API access.
We validate every synthetic dataset against a real-world transfer benchmark before delivery. If the transfer metric does not meet your target, we iterate on the domain randomisation parameters until it does.
Yes. We build high-fidelity digital twins of your deployment environment — down to object placement, lighting conditions, and surface materials — for programs where real-world capture is not feasible.
Tell us the engine and the transfer gap. We come back with a templated scene plan and target metrics.
FROM THE FIELD

For robots operating in the physical world, seeing an object is only the beginning. A robot must also understand how far away it is, where

What a wearable capture rig must carry, why field logistics stall programmes more than engineering does, consent in shared spaces, and quality controls that work.
A robot may have excellent sensors, sophisticated actuators, and a powerful learning model—but if the data used to train that robot is poorly synchronized, the
A robot can see an object without understanding how it feels. A camera can identify a cup, estimate its position, and guide a robotic hand
A mobile robot cannot navigate a warehouse, factory, hospital, or outdoor environment from camera images alone. It needs to understand distance, geometry, obstacles, surfaces, and
Human demonstration and teleoperation produce different action labels with different traps. Plus the third category, intervention data, that most teams never budget for.